Build with
PULSAR HRI's ECOSYSTEM
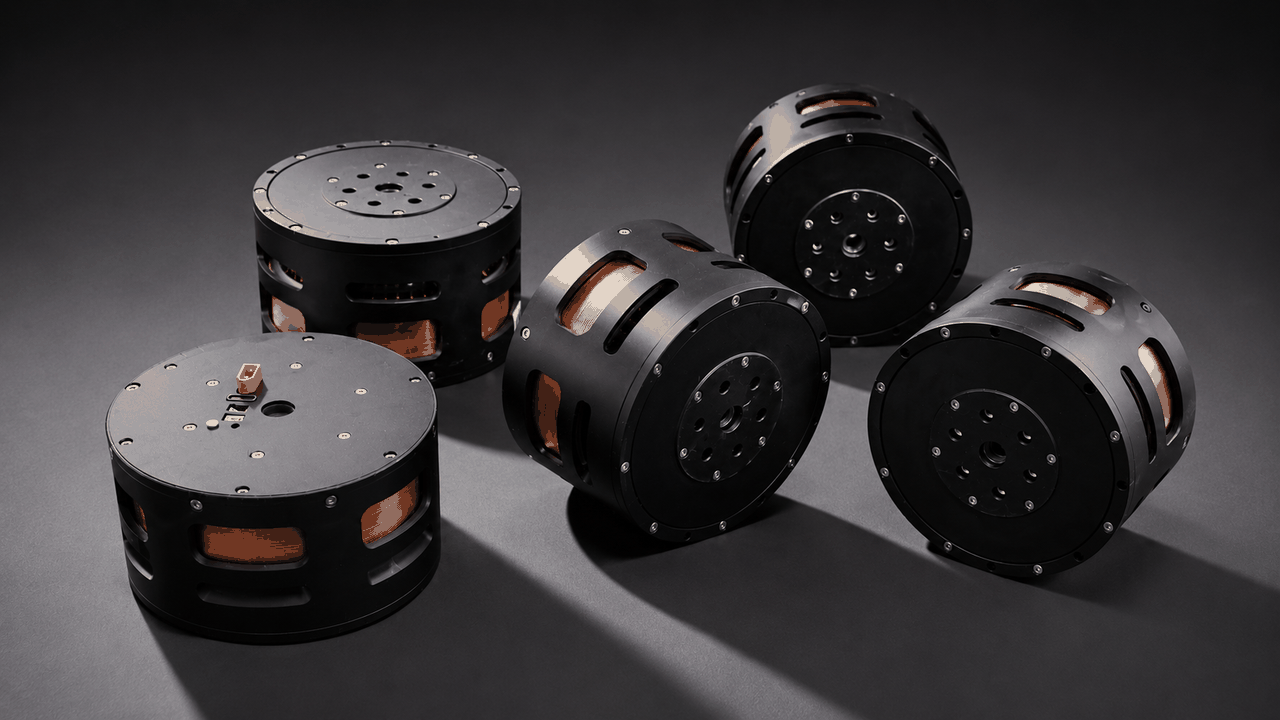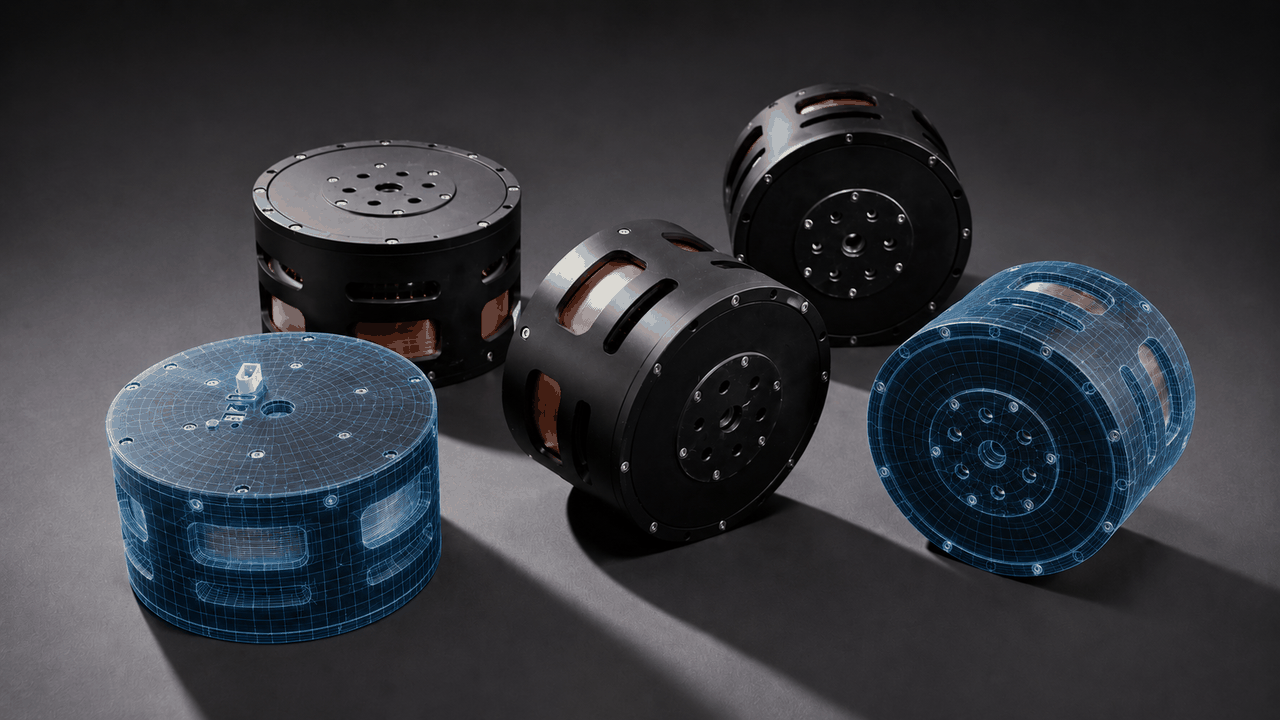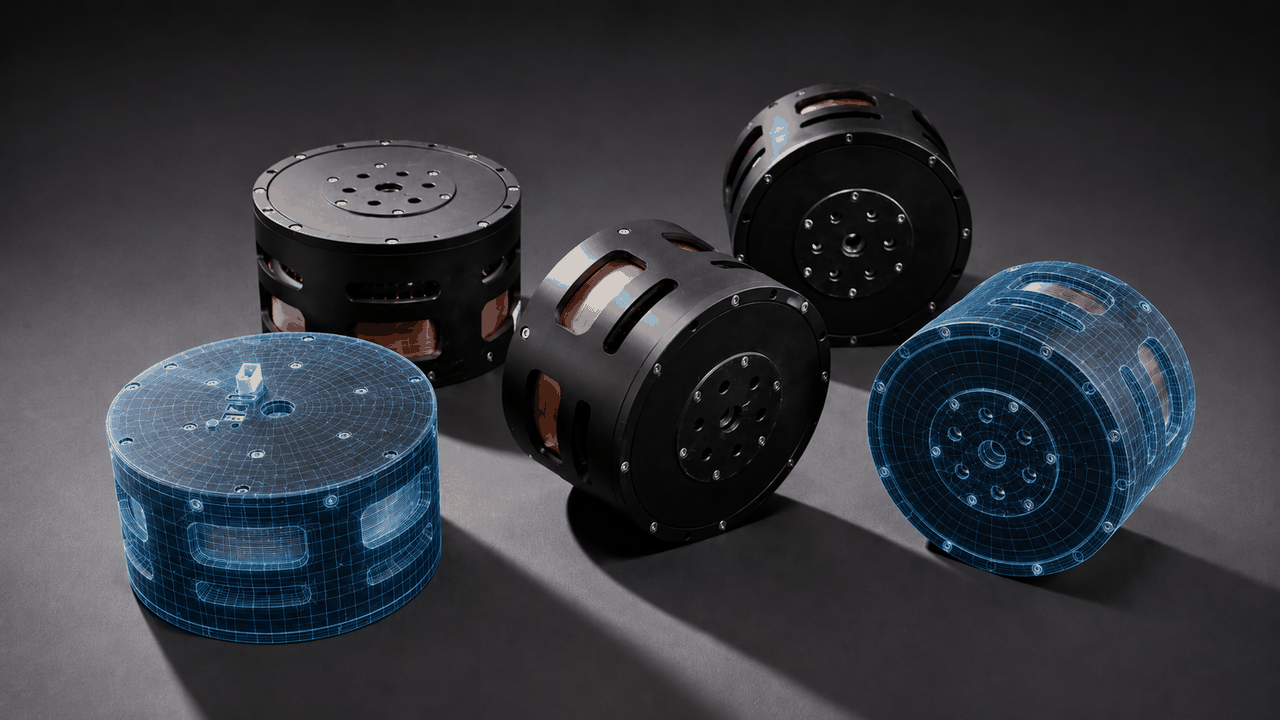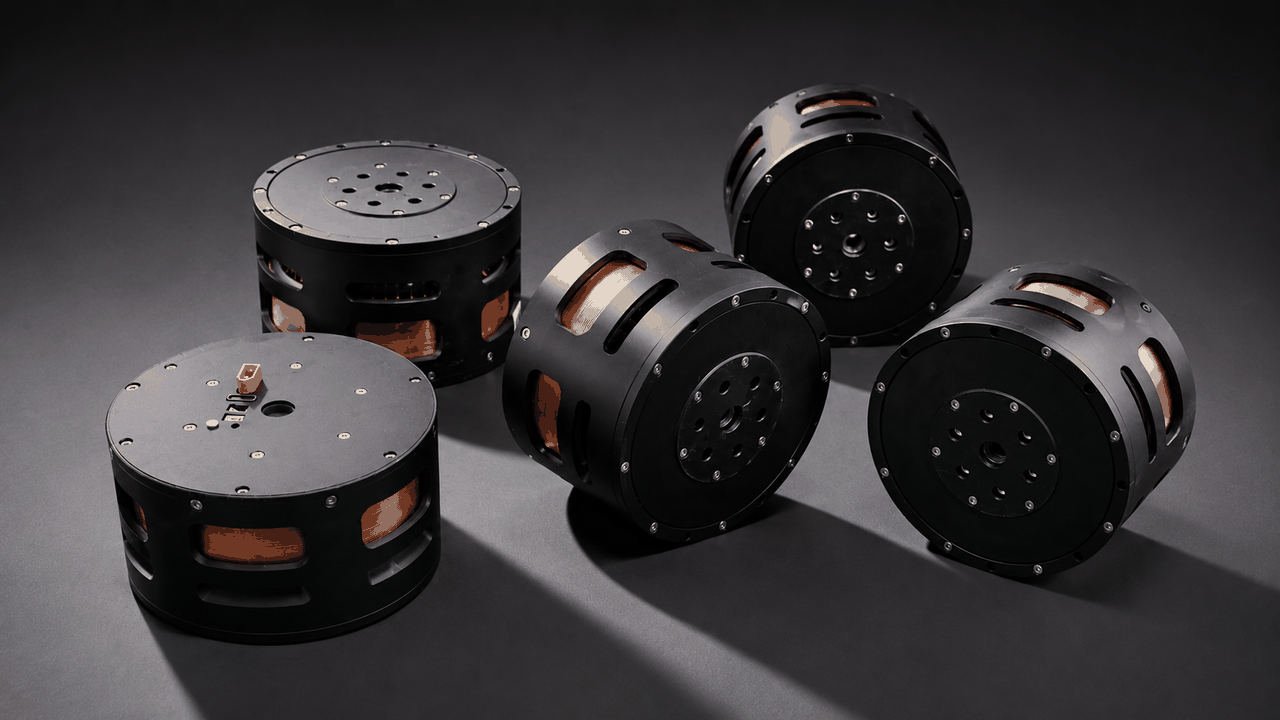
The PULSAR HRI Developer Hub brings together the whole ecosystem of hardware, software, control, and simulation information enabling Developers to build highly dynamic robotics systems for human-robot interaction.
See full catalogue of products and more at pulsarhri.com
Choose your path
| I want to… | Start here |
|---|---|
| Move one physical actuator without code | Pulsar App · direct USB |
| Control one physical actuator with Python | Pulsar Python SDK · direct USB |
| Control several physical actuators with Python | Pulsar Python SDK · CAN FD |
| Develop with a virtual actuator | Pulsar Python SDK · virtual actuators |
| Design a robotic platform | Hardware and AUGUR Digital Twin |
Ecosystem Map
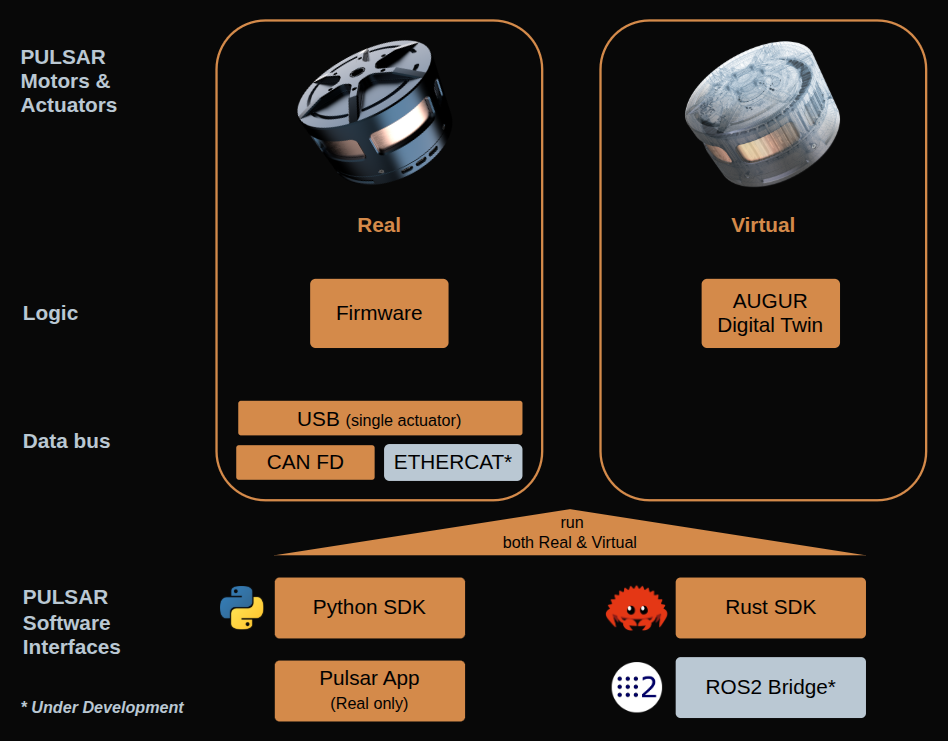
Actuators and Logic
-
Hardware (Real)
Mount and power an actuator, understand its interfaces, and connect by USB or CAN FD.
-
AUGUR Digital Twin (Virtual)
Run validated virtual actuator models and couple them to external robot simulators.
-
Firmware
Learn how the Pulsar App checks for firmware releases and access the current update portal.
-
Control
The physical firmware and AUGUR Digital Twin models run the same low-level control algorithms at 20 kHz.
Software Interfaces
-
Pulsar App
Use the browser or desktop GUI to configure, command, and inspect one physical actuator.
-
Pulsar Python SDK
Build Python applications for physical and virtual actuators, from one device to multi-domain robot platforms.
-
Pulsar Rust SDK
Build actuator applications with the Pulsar Rust SDK.
Compatibility at a glance
- Physical SDK firmware requirement: 2.0.4 or newer.
- Supported hosts: Linux x86_64, Linux ARM64, and Windows x86_64.
- Supported Python versions: 3.10–3.13.
- macOS is not currently supported.
- The Pulsar App controls one physical actuator at a time.
Need help? Visit Support or FAQ and Support.