Control
Control
PULSE actuators provide four user-facing control modes. The physical firmware and AUGUR Digital Twin models run the same low-level control algorithms at 20 kHz.
| Mode | Pulsar Python SDK enum | Primary command |
|---|---|---|
| Torque control | Mode.TORQUE |
torque in N·m |
| Speed/velocity control | Mode.VELOCITY |
angular velocity in rad/s |
| Position control | Mode.POSITION |
output position in rad |
| Impedance control | Mode.IMPEDANCE |
position in rad plus optional impedance fields |
Pulsar App labels velocity mode as Speed Control. Pulsar Python SDK uses the more precise enum name VELOCITY.
Torque
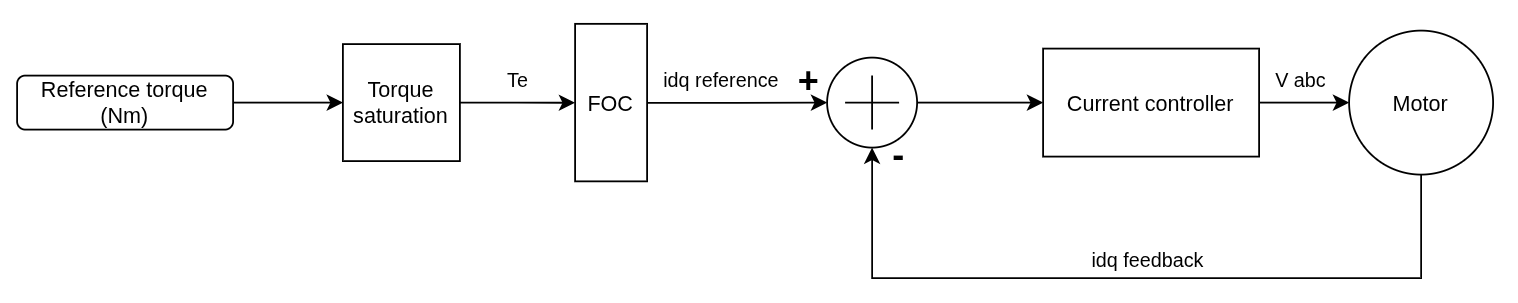
The command is converted to field-oriented current references and regulated by the motor current loop, subject to configured limits.
Velocity
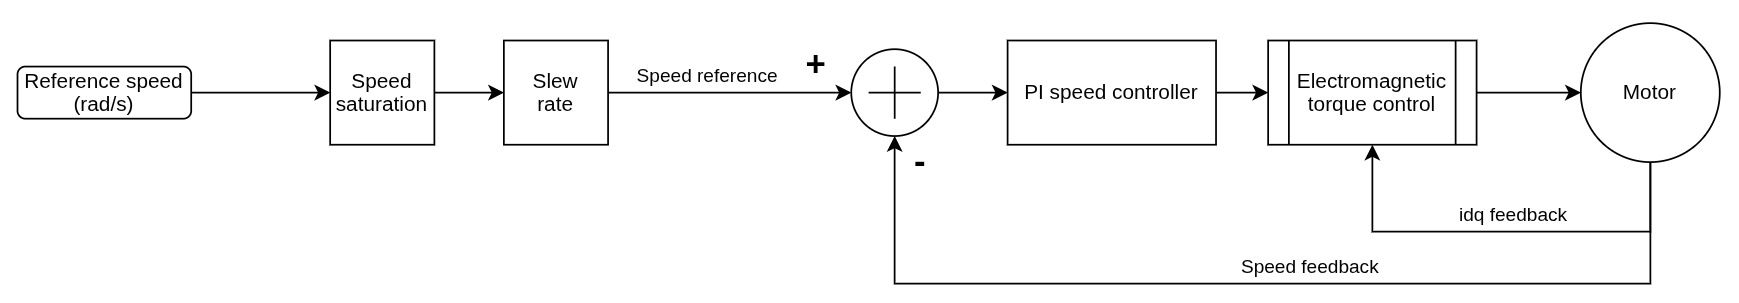
An outer proportional-integral velocity loop produces the torque request for the inner torque/current control loop.
Position
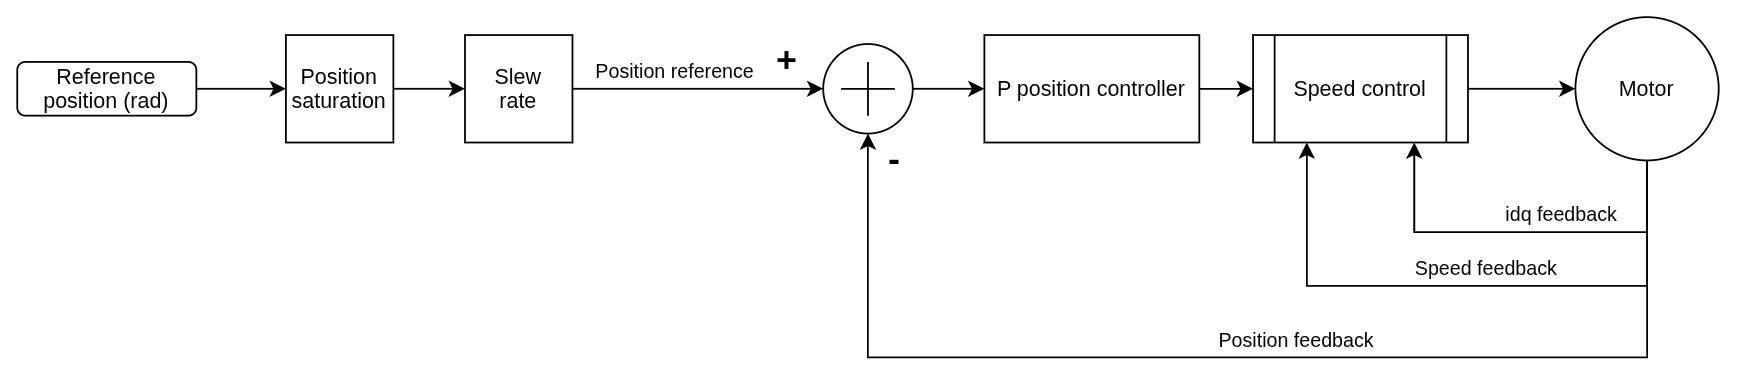
An outer position controller generates a velocity request for the nested velocity and torque loops.
Impedance
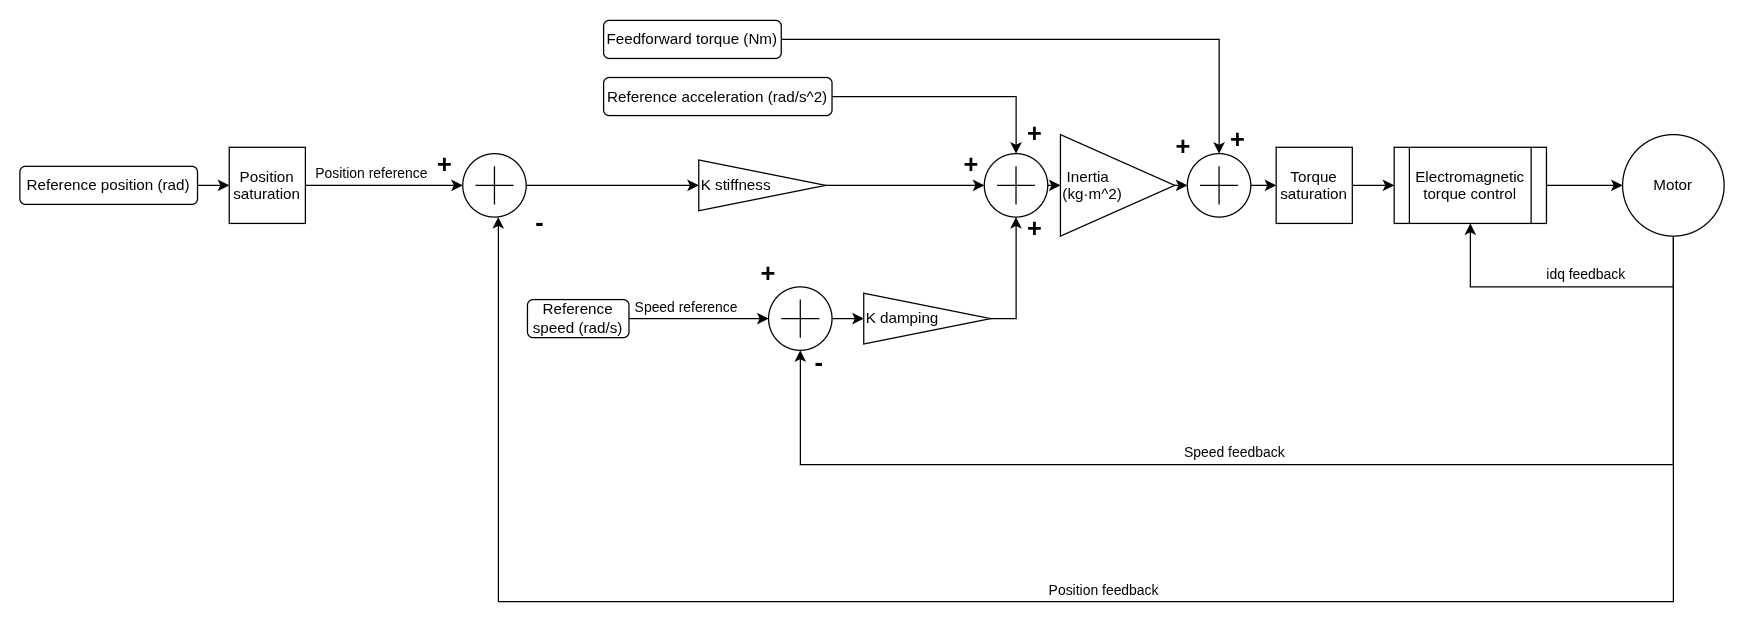
Virtual stiffness, damping, inertia, and feedforward terms produce a compliant torque request from position and velocity behavior.
For valid command fields and persistent parameters, continue with Control parameters by mode.